Blog / Learning Rust on the Robot
the serial
Learning Rust on the Robot
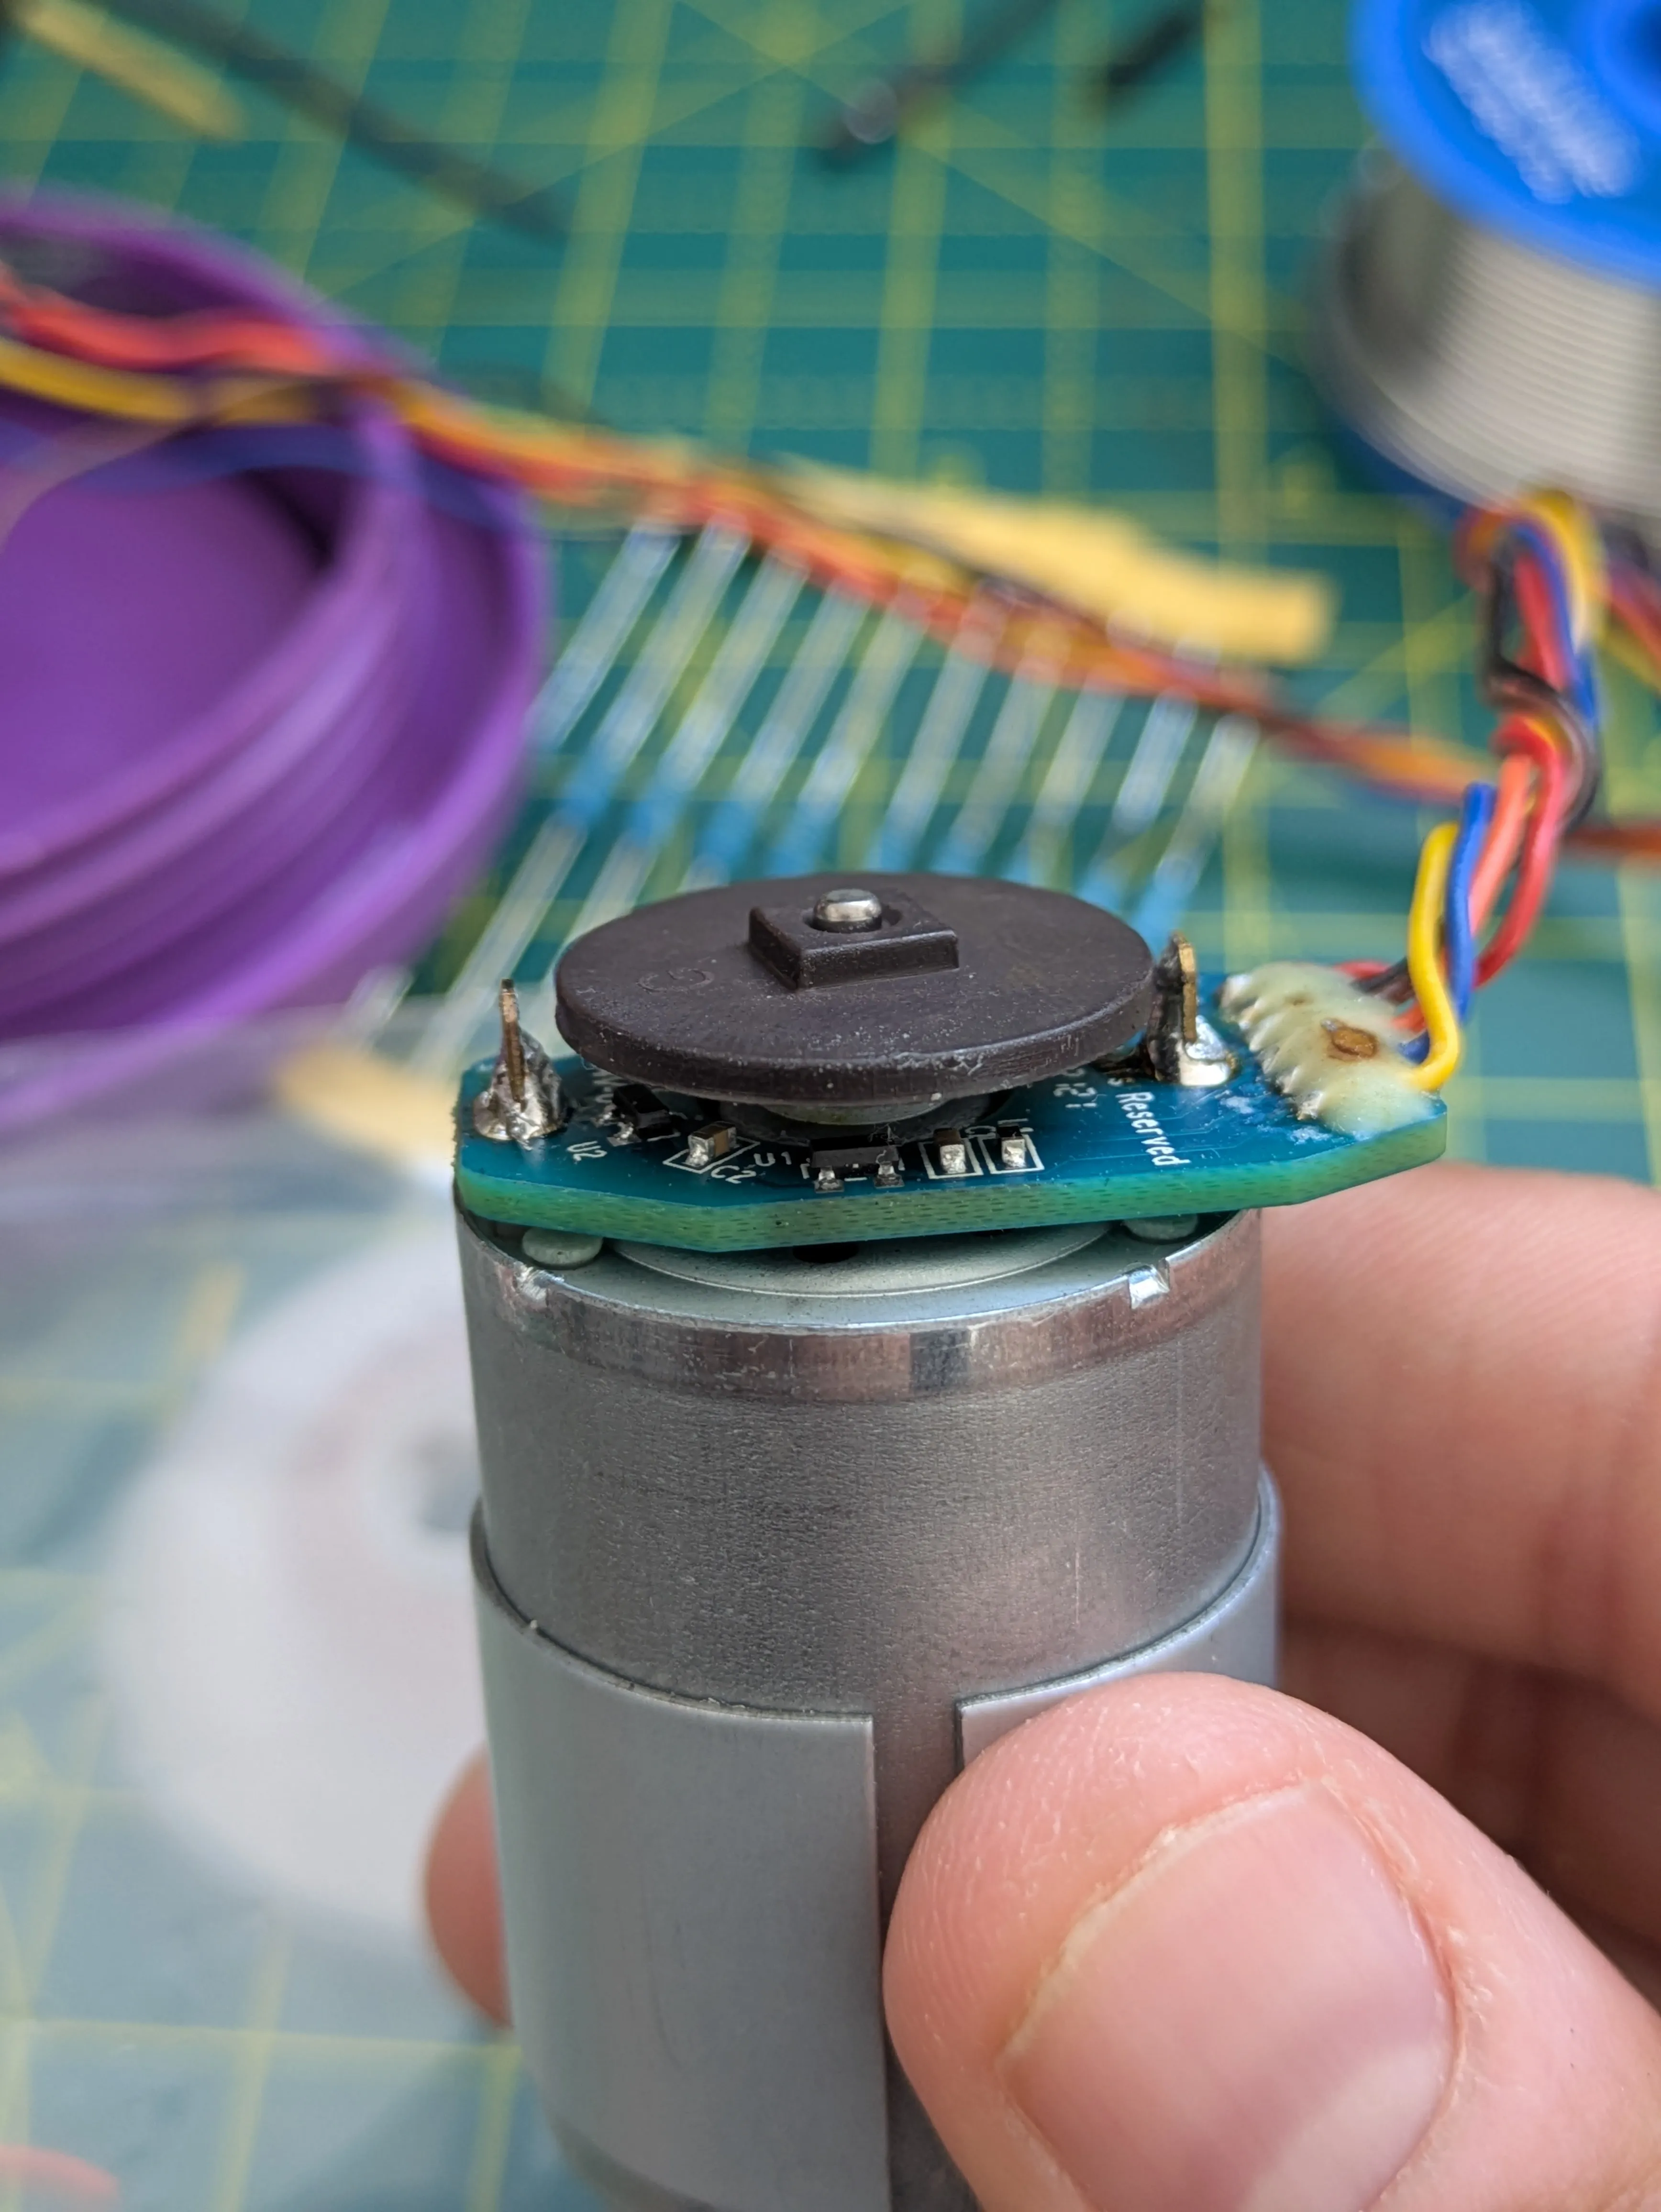
The Neato's ESP32 firmware started life in C++. I'm rebuilding it in Rust — bare-metal, no_std, on real hardware — and turning the motor control into a reusable driver crate. I've written Rust before, but always at arm's length; this is me going deeper on purpose, in the open: toolchain pain, borrow-checker fights, and the refactor from "it works" to "it's a library".
2 episodes In progress
episodes
Learning Rust on the Robot
AUG 10, 2026 · Ep. 2
The wheel that wouldn't stop
Learning Rust on the Robot 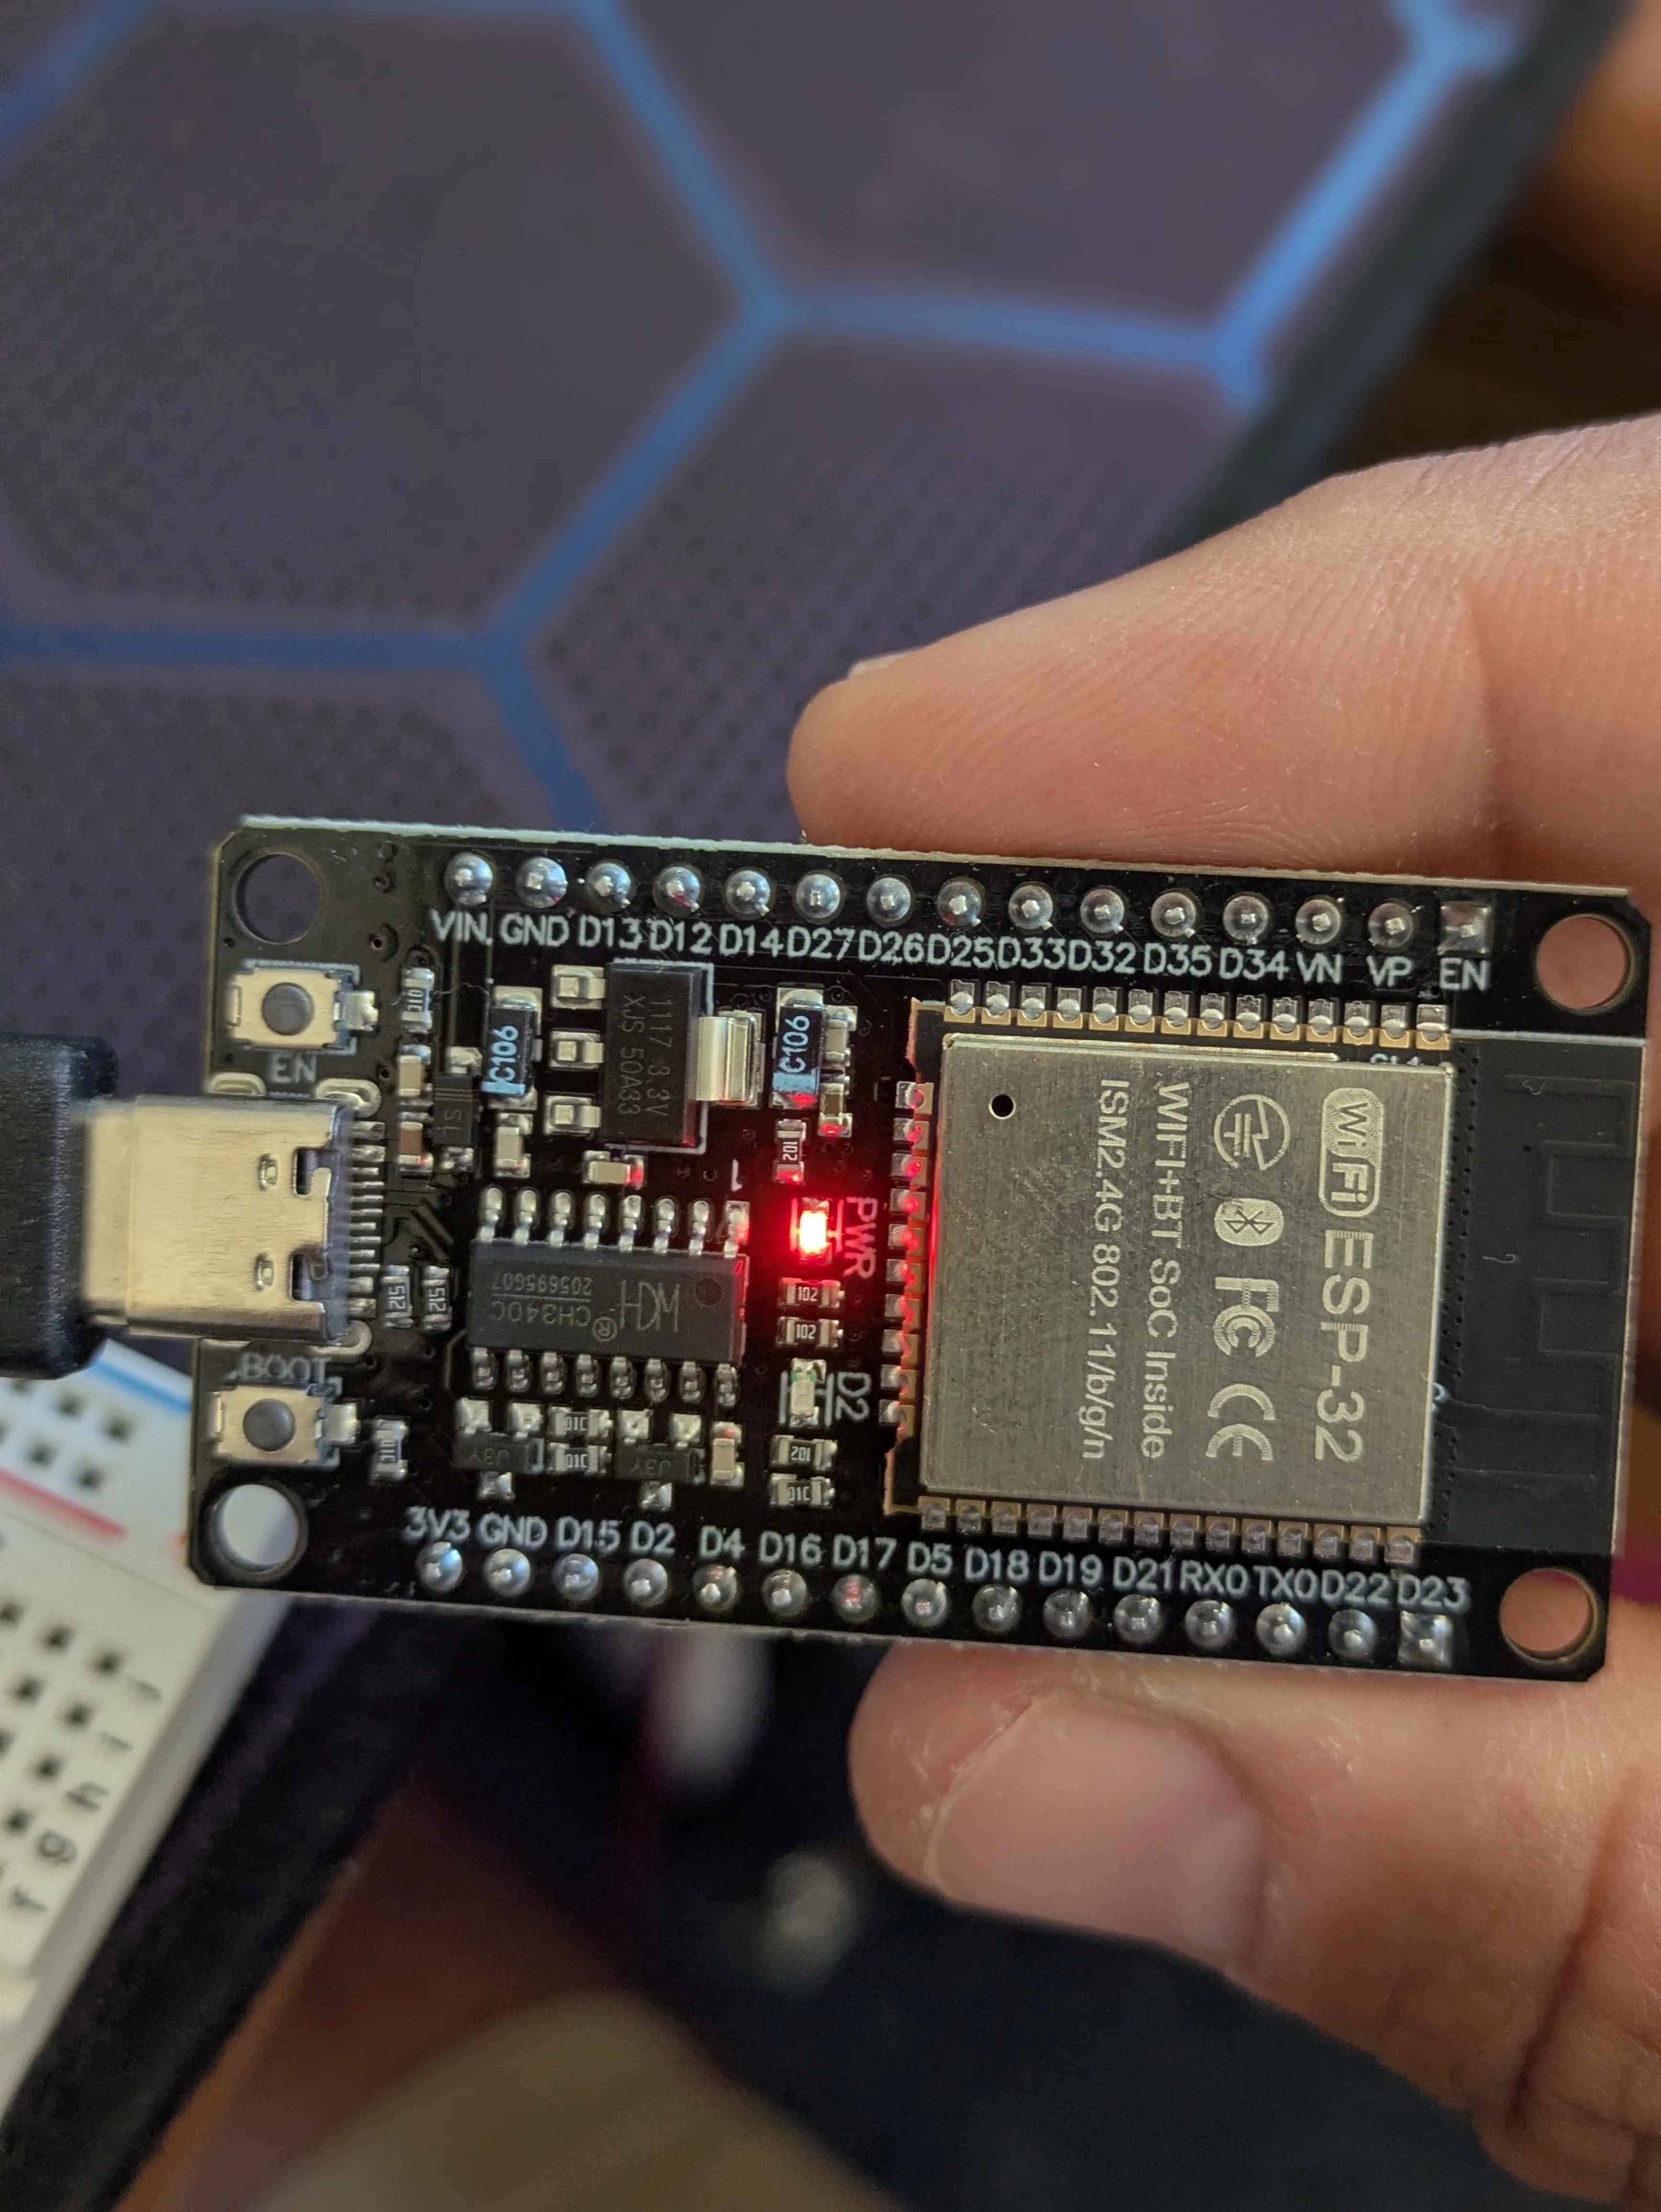
AUG 9, 2026 · Ep. 1
The line I couldn't give back
reference
The living docs — always current, unlike the episodes (which are snapshots in time).